The World's First Self-Evolving Leaderboard for Heterogeneous Multi-Robot Collaboration
English · 简体中文
Project website · Dataset · Tasks · Evaluation · RSI · Get started
| Training demonstrations | Task families | Robot teams | RSI | | :---: | :---: | :---: | :---: | | **2,000+** | **20+** · 100 demos each | **2 / 3 / 4 / 8 arms** | **Learn & Evolve** | ## Collaboration in action [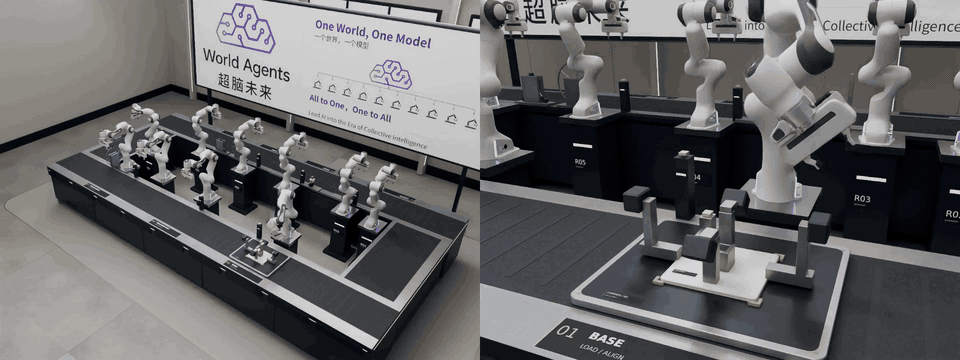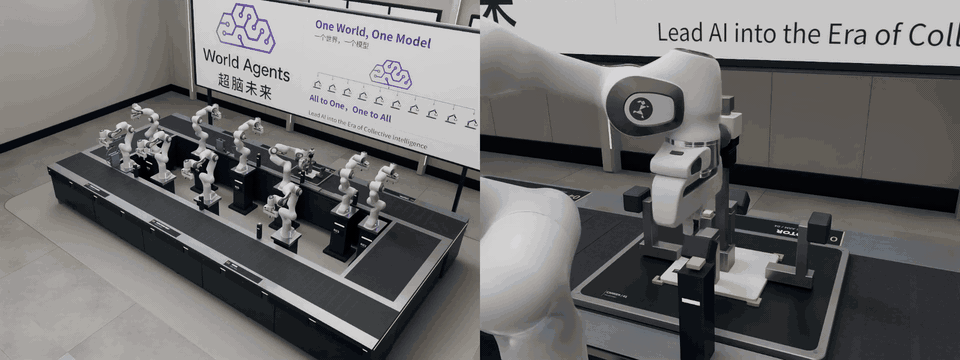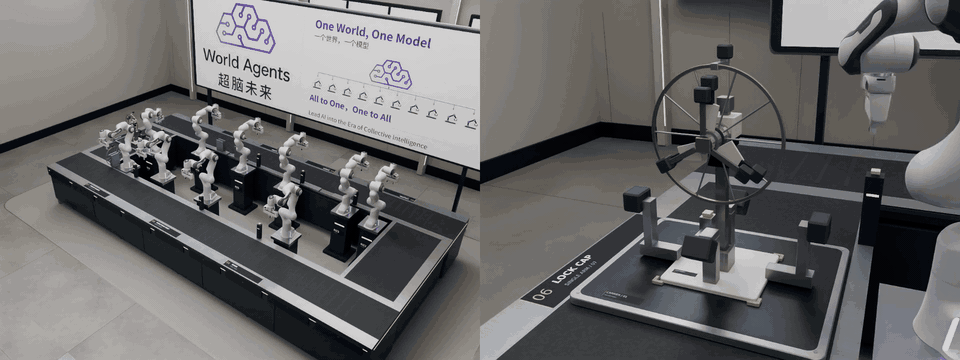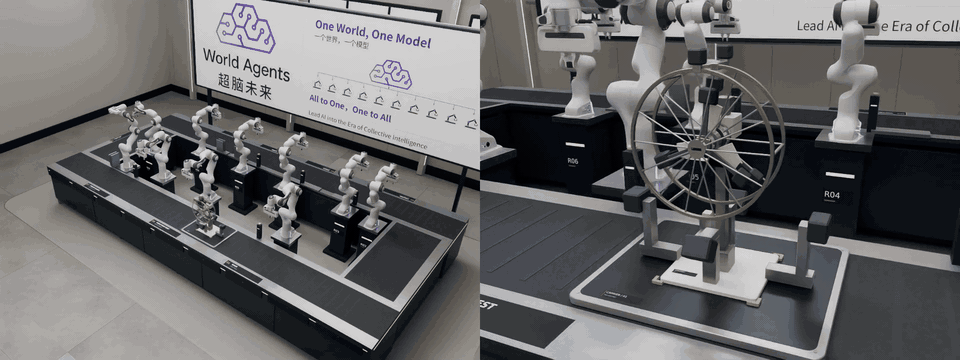](assets/fan-isomorphic.mp4)▶ Watch the complete ten-arm assembly · Watch the collection overview
Ten matching arms share an assembly sequence, transferring a workpiece between stations and coordinating each step toward a completed fan. ## Dataset **A balanced collection of 2,000+ reviewed simulation demonstrations across 20+ collaborative manipulation tasks.** Each task contributes 100 episodes, covering handovers, relays, shared transport, ordered stacking, and parallel manipulation. [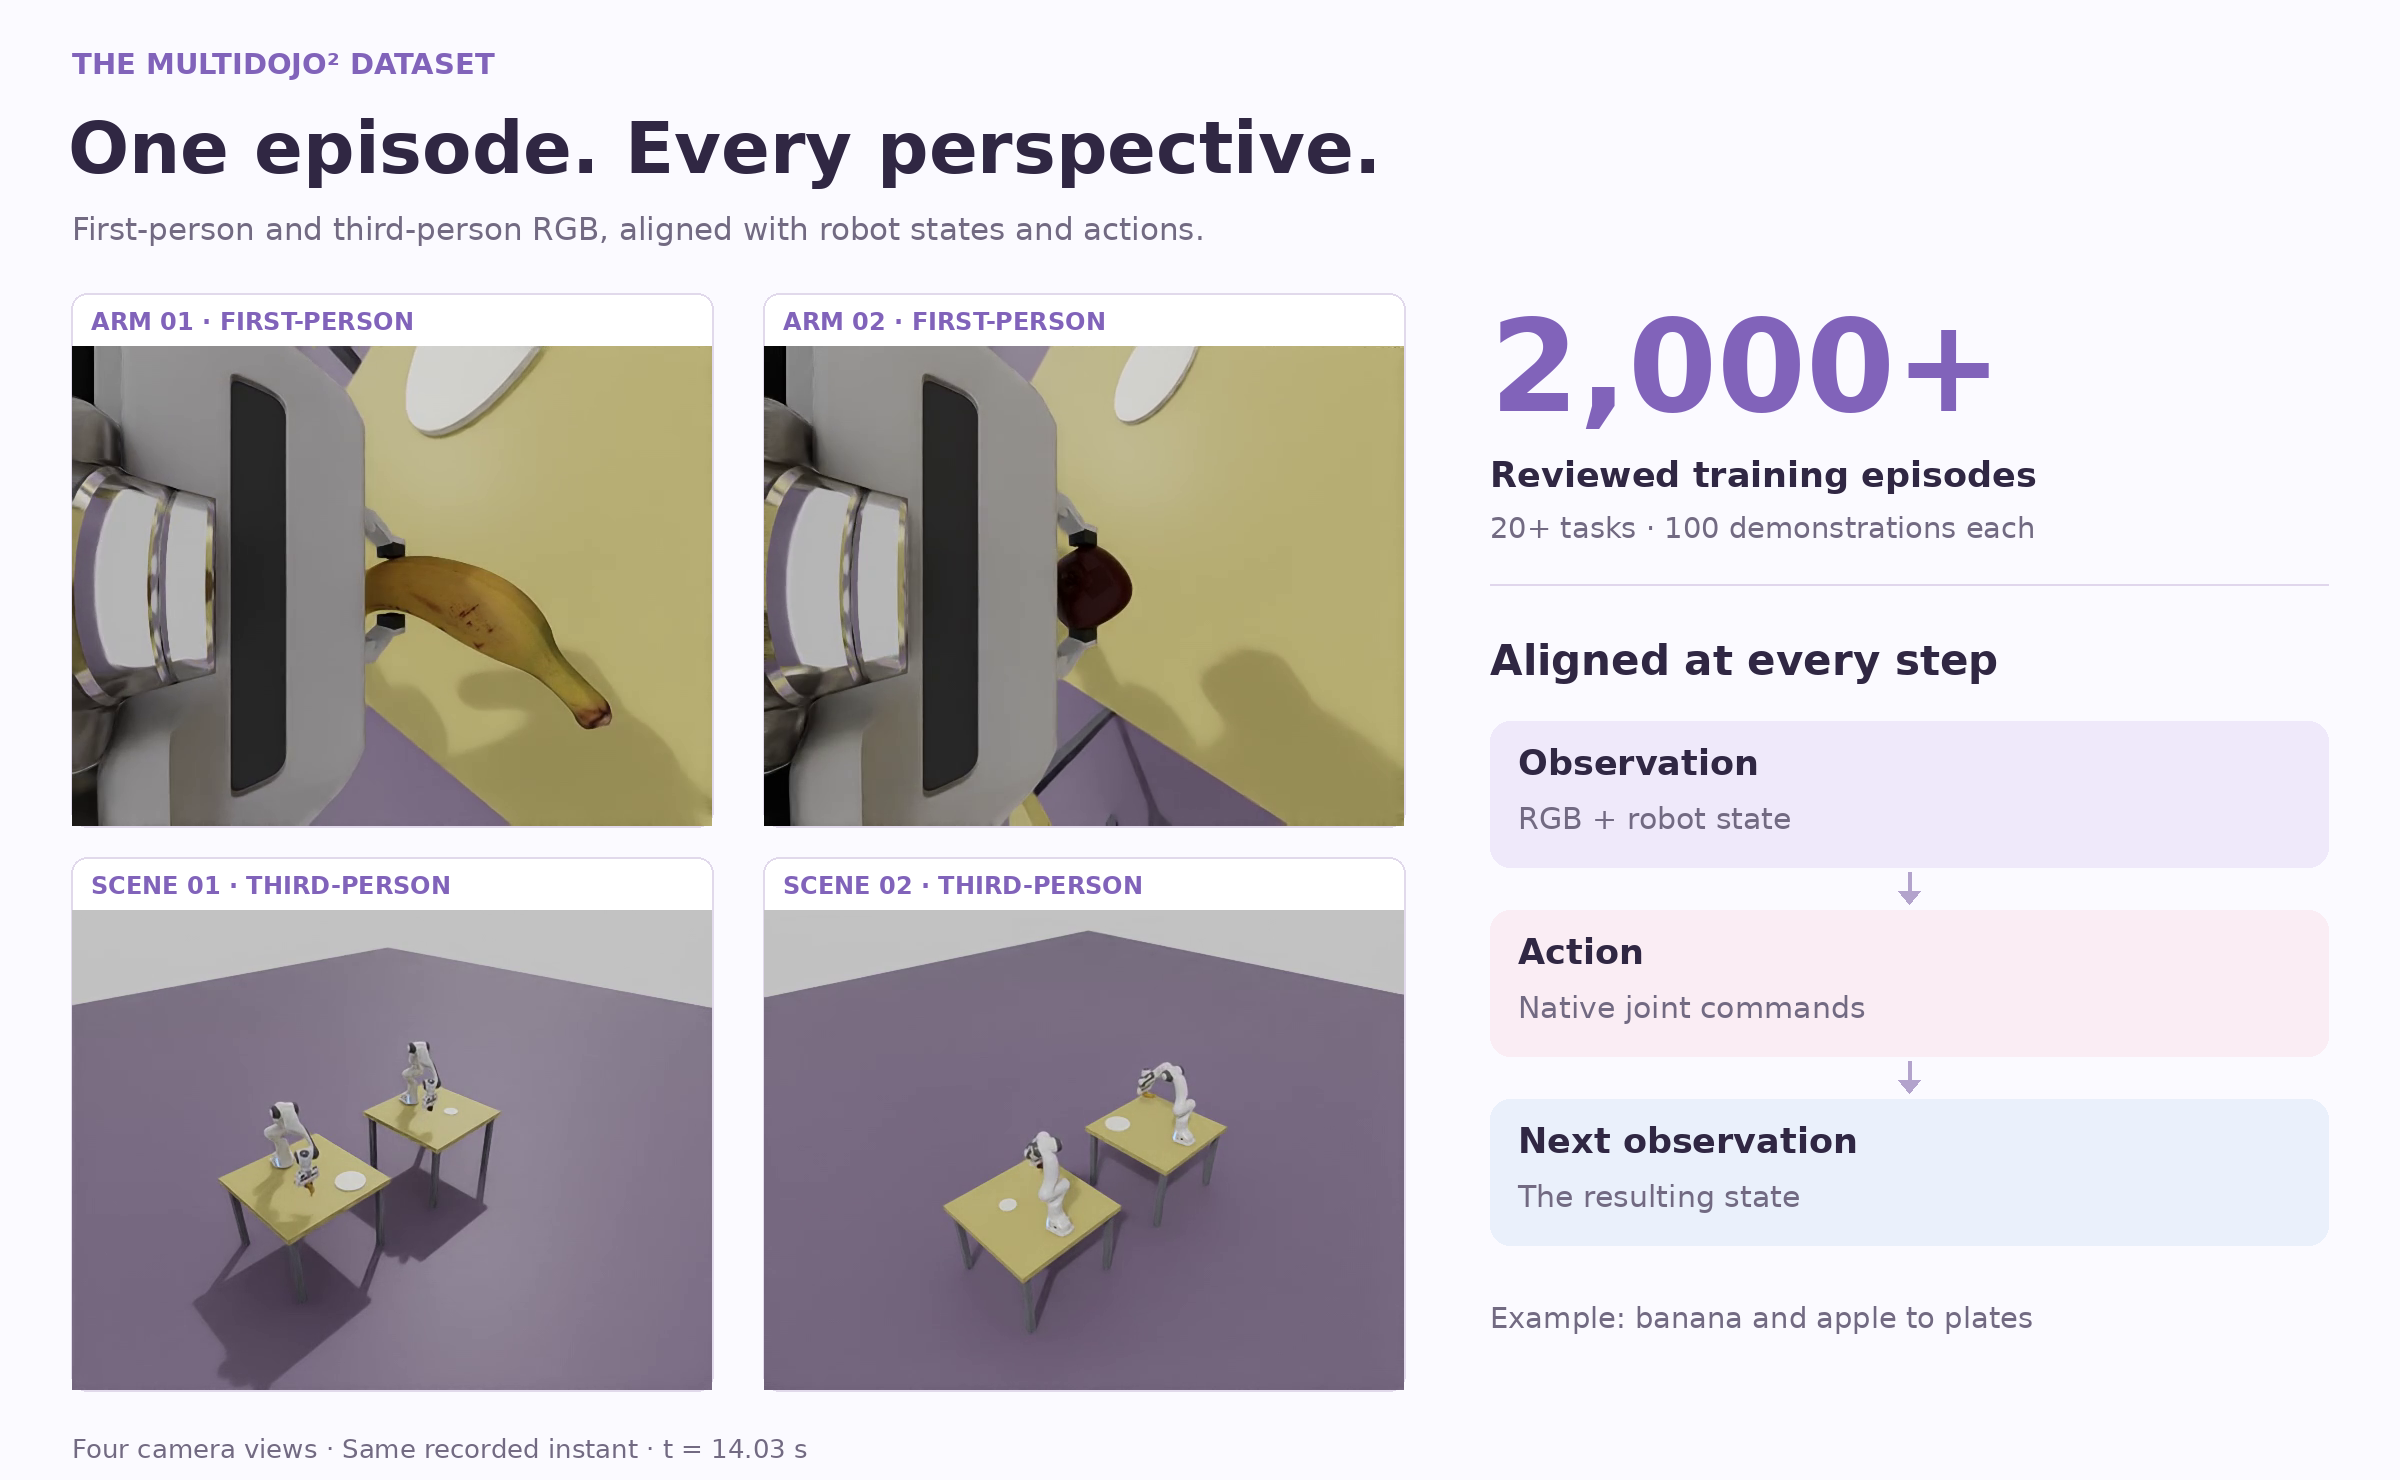](assets/dataset-perspectives.png) - **See the team and the local interaction.** Every arm has a first-person view, accompanied by third-person views of the shared workspace. Follow grasping details and inter-robot coordination on the same timeline. - **Learn from aligned observations and actions.** RGB, robot state, native joint commands, next observations, and camera calibration preserve the connection between what each robot sees and how it moves. - **Study collaboration across robot designs.** Homogeneous and heterogeneous teams span two, three, four, and eight arms. Native joint orders, units, and actuator masks retain each robot's control semantics. - **Explore meaningful scene variation.** Object and goal positions, workspaces, and scene appearance vary while preserving the task's manipulation objective. - **Use physically reviewed episodes.** Acceptance checks cover grasping and contact, object support, placement stability, arm-to-arm collision constraints, synchronized images, and file integrity. **[Download training data on Hugging Face →](https://huggingface.co/datasets/WorldAgents-c/MultiDojo2)** The **2,000+ demonstration collection** is being progressively released on Hugging Face, with synchronized first-person and third-person views, native states/actions, and acceptance metadata. Download and loading instructions are provided in the dataset repository. [Data format & loader example →](PROJECT.md#dataset) · [Machine-readable task catalog →](assets/task-catalog.json)▶ Watch the complete heterogeneous assembly
▶ Watch the complete humanoid–manipulator assembly
*Fan assembly highlights long-horizon, multi-stage coordination across homogeneous, heterogeneous, and humanoid teams.* ## All-to-One. One-to-All. **Robot automation scales through collaboration.** Shared tasks call for a shared understanding of the workspace, coordinated timing, and actions suited to each robot's role. **All-to-One** brings observations and states into a common view of the world. **One-to-All** turns that shared understanding into coordinated actions across different robots. **One World, One Model** expresses the research vision behind this approach. 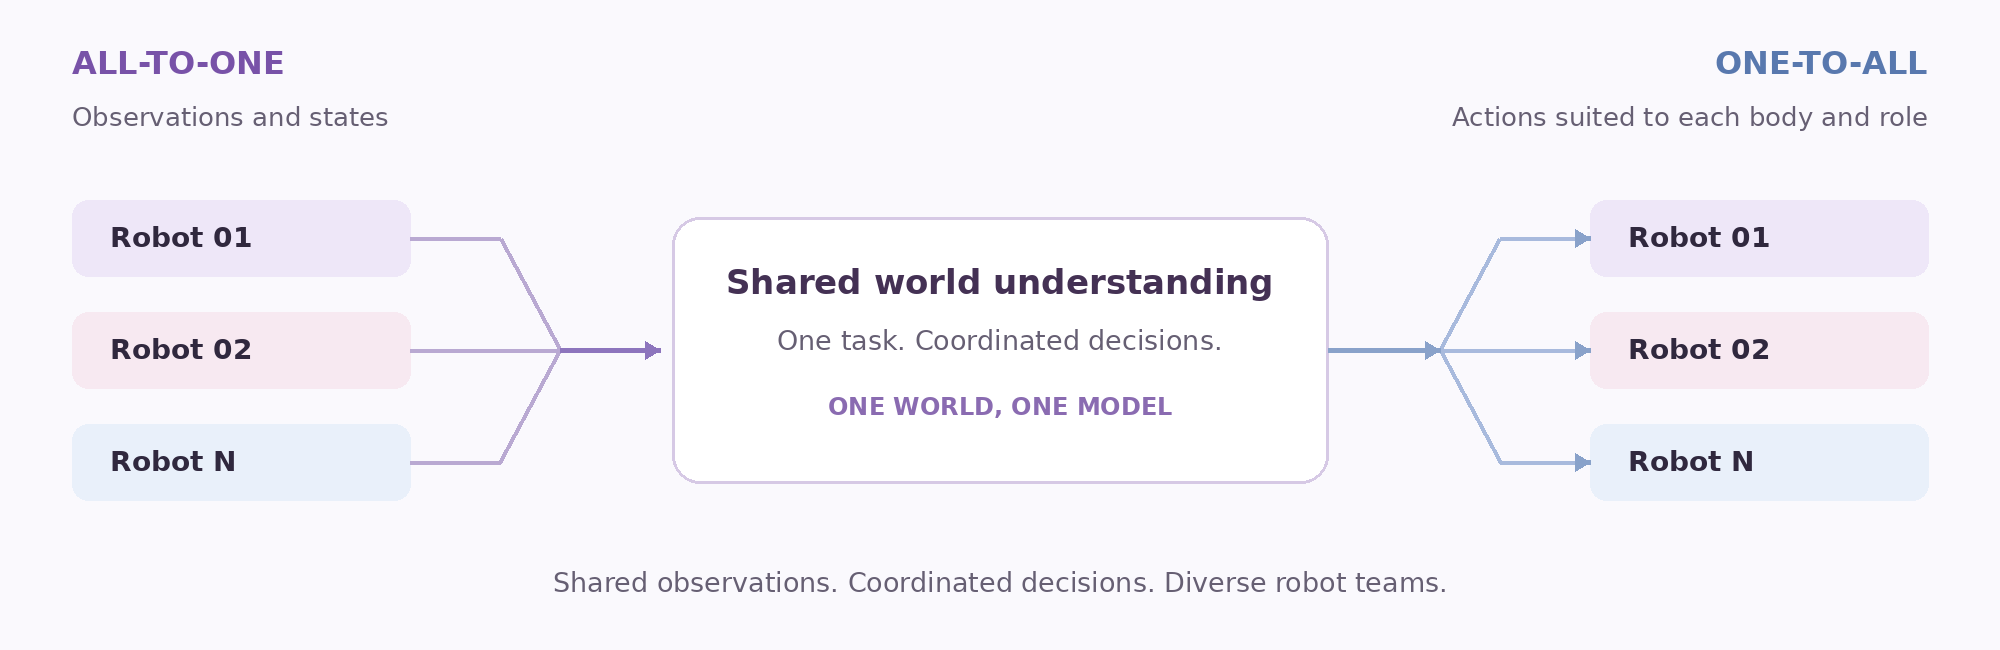 ## Tasks The suite spans **five collaboration skills**: handover, relay, shared lifting, stacking, and parallel manipulation. Each task includes **100 training demonstrations**, with evaluation designed around varied scene conditions and initial states. | ID | Task | Team | Skill | | --- | --- | --- | --- | | 00 | Banana handover into a pan | Homogeneous · 2 arms | Handover | | 01 | Banana and apple to plates | Homogeneous · 2 arms | Parallel manipulation | | 02 | Collaborative carton transport | Homogeneous · 2 arms | Shared lifting | | 03 | Two-stage cup relay | Homogeneous · 2 arms | Relay | | 04 | Place and stack blocks | Homogeneous · 2 arms | Stacking | | 05 | Franka–Piper long-block handover | Heterogeneous · 2 arms | Handover | | 06 | Three-arm block relay | Homogeneous · 3 arms | Relay | | 07 | Apples to baskets | Homogeneous · 4 arms | Parallel manipulation | | 08 | Four-arm block relay | Homogeneous · 4 arms | Relay | | 09 | Ordered four-color stacking | Homogeneous · 4 arms | Stacking | | 10 | Cookies to boxes | Homogeneous · 4 arms | Parallel manipulation | | 11 | Household objects to boxes | Homogeneous · 4 arms | Parallel manipulation | | 12 | Eight-arm blocks to boxes | Homogeneous · 8 arms | Parallel manipulation | | 13 | Three-arm block relay | Heterogeneous · 3 arms | Relay | | 14 | Four-arm block relay | Heterogeneous · 4 arms | Relay | | 15 | Eight-arm blocks to boxes | Heterogeneous · 8 arms | Parallel manipulation | | 16 | Three-arm banana relay | Heterogeneous · 3 arms | Relay | | 17 | Three-arm white-cup relay | Heterogeneous · 3 arms | Relay | | 18 | Four-arm banana relay | Heterogeneous · 4 arms | Relay | | 19 | Four-arm white-cup relay | Heterogeneous · 4 arms | Relay |00 BananaDualArmHandover 01 IsomorphicDualArm/BananaAppleToPlates 02 IsomorphicDualArm/CollabLiftLongBox 03 IsomorphicDualArm/CupLeftToMidToRight 04 IsomorphicDualArm/LeftPlaceRightStack 05 HeterogeneousDualArm/FrankPiperBananaHandover 06 IsomorphicTripleArm/BlockZoneRelay 07 IsomorphicQuadArm/AppleToBasket 08 IsomorphicQuadArm/BlockZoneRelay 09 IsomorphicQuadArm/ColorBlockCenterStack 10 IsomorphicQuadArm/CookieToBox 11 IsomorphicQuadArm/HouseholdToBox 12 IsomorphicOctaArm/BlocksToBoxes 13 HeterogeneousTripleArm/BlockZoneRelay 14 HeterogeneousQuadArm/BlockZoneRelay 15 HeterogeneousOctaArm/BlocksToBoxes 16 HeterogeneousTripleArm/BananaZoneRelay 17 HeterogeneousTripleArm/WhiteCupZoneRelay 18 HeterogeneousQuadArm/BananaZoneRelay 19 HeterogeneousQuadArm/WhiteCupZoneRelay